

ISO 16328
(Main)Ships and marine technology — Gyro-compasses for high-speed craft
General Information
- Abstract
This International Standard specifies the construction, performance, and type testing for gyro-compass for high-speed craft required by chapter X, SOLAS 1974 (as amended). NOTE All requirements that are extracted from the recommendations of IMO Resolutions [Resolution A.821(19) on performance standards for gyro-compasses for high-speed craft and A.694(17)] are printed in italics. The main changes compared to the present edition are as follows; — Requirements related to bridge alert management (BAM) will be added to the clause of requirements and type test. — IEC 61162-450 will be added to the clause of interface as an option. — The normative references and bibliography will be updated. — Editorial revision of the standard in general according to the ISO/IEC Directives, Part 2 — Additionally, Annex will be added as alert definitions and IEC 61162 interface overviews for further explanation of the above.
- Status
- Not Published
- Technical Committee
- ISO/TC 8/SC 6 - Navigation and ship operations
- Drafting Committee
- ISO/TC 8/SC 6 - Navigation and ship operations
- Current Stage
- 6000 - International Standard under publication
- Start Date
- 18-Sep-2026
- Completion Date
- 26-Sep-2026
Buy Documents
ISO/FDIS 16328 - Ships and marine technology — Gyro-compasses for high-speed craft
REDLINE ISO/FDIS 16328 - Ships and marine technology — Gyro-compasses for high-speed craft
Overview
ISO 16328: Ships and Marine Technology - Gyro-Compasses for High-Speed Craft is an internationally recognized standard developed by ISO’s Technical Committee 8 (ISO/TC 8/SC 6). It specifically addresses the construction, performance, and type testing requirements for gyro-compasses intended for high-speed craft, ensuring compliance with Chapter X of the SOLAS 1974 Convention (as amended) and performance standards from IMO Resolution A.821(19).
This standard aims to guarantee that gyro-compasses installed on high-speed vessels-typically those operating at speeds exceeding 30 knots-are reliable, accurate, and seamlessly integrated with onboard navigation systems. ISO 16328 also incorporates essential requirements for bridge alert management (BAM), digital interfaces (including the optional IEC 61162-450 Ethernet), and updated normative references, which enhance operational safety and equipment interoperability.
Key Topics
Construction Requirements:
- Clear criteria for the design and assembly of gyro-compass equipment and bearing repeater compasses.
- Stipulation of continuous operation under maritime environmental conditions (vibration, humidity, variable temperature, power supply fluctuations).
- Prescribed compass card graduation, digital display options, illumination, and marking for accurate heading reading.
- Specific installation guidance for both master compasses and repeaters to ensure correct alignment and function.
- Inclusion of robust speed error correction using approved speed information sources.
Performance and Testing:
- Accuracy requirements up to 70° latitude, including settling time, settle point error, and performance under motion (rolling, pitching, yawing).
- Synchronization tolerances between master and repeater compasses.
- Type testing procedures for heading accuracy, repeatability, speed error correction, vibration, temperature resilience, and more.
- Verification of interface compatibility and bridge alert management.
Interface and Alert Management:
- Support for integration with navigational aids (e.g., radar, ARPA, heading control systems), without performance degradation.
- Optional support for IEC 61162-450 Ethernet for enhanced communication with external equipment like VDR (Voyage Data Recorder).
- Structured alert management aligned with IMO and IEC requirements, including definitions and test methods for power fail and system fault alerts.
Applications
ISO 16328 is essential for:
- Manufacturers: Ensuring that gyro-compasses for high-speed craft meet stringent safety, performance, and interoperability requirements.
- Shipyards and Integrators: Proper selection, installation, and testing of gyro-compass systems during new builds or retrofits, ensuring compliance with SOLAS and IMO regulations.
- Ship Operators and Owners: Enhancing navigational safety for high-speed craft through reliable, accurate heading information and robust alert systems.
- Maritime Surveyors and Certification Bodies: Assessing onboard gyro-compass installations per ISO 16328’s detailed annexes regarding installation and test procedures.
- System Designers: Incorporating up-to-date interfaces and alert management protocols for integrated bridge systems.
Related Standards
ISO 16328 references and aligns with several international guidelines and standards to ensure comprehensive marine navigation requirements, including:
- IEC 60945: General requirements and environmental testing for maritime navigation and radiocommunication equipment.
- IEC 61162 Series: Standards for digital communication interfaces between marine navigation and radiocommunication equipment, including IEC 61162-1, IEC 61162-2 (high-speed), and IEC 61162-450 (Ethernet).
- IEC 62288: Guidelines for the presentation of navigation-related information.
- IEC 62923 Series: Bridge alert management requirements and testing.
- IMO Resolutions:
- A.821(19): Performance standards for gyro-compasses for high-speed craft.
- A.424(XI), MSC.302(87), MSC.191(79): Additional navigational display and alert management standards.
- A.694(17): General requirements for shipborne radio and navigational equipment.
Adherence to ISO 16328 ensures high-speed craft benefit from advanced, reliable, and standardized gyro-compass systems, supporting operational safety and international regulatory compliance.
Relations
- Effective Date
- 06-Jun-2022
Buy Documents
ISO/FDIS 16328 - Ships and marine technology — Gyro-compasses for high-speed craft
REDLINE ISO/FDIS 16328 - Ships and marine technology — Gyro-compasses for high-speed craft
Get Certified
Connect with accredited certification bodies for this standard
DNV
DNV is an independent assurance and risk management provider.
Lloyd's Register
Lloyd's Register is a global professional services organisation specialising in engineering and technology.
FSC International
Forest Stewardship Council certification.
Sponsored listings
Frequently Asked Questions
ISO 16328 is a draft published by the International Organization for Standardization (ISO). Its full title is "Ships and marine technology — Gyro-compasses for high-speed craft". This standard covers: This International Standard specifies the construction, performance, and type testing for gyro-compass for high-speed craft required by chapter X, SOLAS 1974 (as amended). NOTE All requirements that are extracted from the recommendations of IMO Resolutions [Resolution A.821(19) on performance standards for gyro-compasses for high-speed craft and A.694(17)] are printed in italics. The main changes compared to the present edition are as follows; — Requirements related to bridge alert management (BAM) will be added to the clause of requirements and type test. — IEC 61162-450 will be added to the clause of interface as an option. — The normative references and bibliography will be updated. — Editorial revision of the standard in general according to the ISO/IEC Directives, Part 2 — Additionally, Annex will be added as alert definitions and IEC 61162 interface overviews for further explanation of the above.
This International Standard specifies the construction, performance, and type testing for gyro-compass for high-speed craft required by chapter X, SOLAS 1974 (as amended). NOTE All requirements that are extracted from the recommendations of IMO Resolutions [Resolution A.821(19) on performance standards for gyro-compasses for high-speed craft and A.694(17)] are printed in italics. The main changes compared to the present edition are as follows; — Requirements related to bridge alert management (BAM) will be added to the clause of requirements and type test. — IEC 61162-450 will be added to the clause of interface as an option. — The normative references and bibliography will be updated. — Editorial revision of the standard in general according to the ISO/IEC Directives, Part 2 — Additionally, Annex will be added as alert definitions and IEC 61162 interface overviews for further explanation of the above.
ISO 16328 is classified under the following ICS (International Classification for Standards) categories: 47.020.70 - Navigation and control equipment. The ICS classification helps identify the subject area and facilitates finding related standards.
ISO 16328 has the following relationships with other standards: It is inter standard links to ISO 16328:2014. Understanding these relationships helps ensure you are using the most current and applicable version of the standard.
ISO 16328 is available in PDF format for immediate download after purchase. The document can be added to your cart and obtained through the secure checkout process. Digital delivery ensures instant access to the complete standard document.
Standards Content (Sample)
FINAL DRAFT
International
Standard
ISO/FDIS 16328
ISO/TC 8/SC 6
Ships and marine technology —
Secretariat: JISC
Gyro-compasses for high-speed
Voting begins on:
craft
2026-07-23
Navires et technologie maritime — Compas gyroscopiques pour
Voting terminates on:
navires à grande vitesse
2026-09-17
RECIPIENTS OF THIS DRAFT ARE INVITED TO SUBMIT,
WITH THEIR COMMENTS, NOTIFICATION OF ANY
RELEVANT PATENT RIGHTS OF WHICH THEY ARE AWARE
AND TO PROVIDE SUPPOR TING DOCUMENTATION.
IN ADDITION TO THEIR EVALUATION AS
BEING ACCEPTABLE FOR INDUSTRIAL, TECHNO
LOGICAL, COMMERCIAL AND USER PURPOSES, DRAFT
INTERNATIONAL STANDARDS MAY ON OCCASION HAVE
TO BE CONSIDERED IN THE LIGHT OF THEIR POTENTIAL
TO BECOME STAN DARDS TO WHICH REFERENCE MAY BE
MADE IN NATIONAL REGULATIONS.
Reference number
ISO/FDIS 16328:2026(en) © ISO 2026
FINAL DRAFT
ISO/FDIS 16328:2026(en)
International
Standard
ISO/FDIS 16328
ISO/TC 8/SC 6
Ships and marine technology —
Secretariat: JISC
Gyro-compasses for high-speed
Voting begins on:
craft
Navires et technologie maritime — Compas gyroscopiques pour
Voting terminates on:
navires à grande vitesse
RECIPIENTS OF THIS DRAFT ARE INVITED TO SUBMIT,
WITH THEIR COMMENTS, NOTIFICATION OF ANY
RELEVANT PATENT RIGHTS OF WHICH THEY ARE AWARE
AND TO PROVIDE SUPPOR TING DOCUMENTATION.
© ISO 2026
IN ADDITION TO THEIR EVALUATION AS
All rights reserved. Unless otherwise specified, or required in the context of its implementation, no part of this publication may
BEING ACCEPTABLE FOR INDUSTRIAL, TECHNO
LOGICAL, COMMERCIAL AND USER PURPOSES, DRAFT
be reproduced or utilized otherwise in any form or by any means, electronic or mechanical, including photocopying, or posting on
INTERNATIONAL STANDARDS MAY ON OCCASION HAVE
the internet or an intranet, without prior written permission. Permission can be requested from either ISO at the address below
TO BE CONSIDERED IN THE LIGHT OF THEIR POTENTIAL
or ISO’s member body in the country of the requester.
TO BECOME STAN DARDS TO WHICH REFERENCE MAY BE
MADE IN NATIONAL REGULATIONS.
ISO copyright office
CP 401 • Ch. de Blandonnet 8
CH-1214 Vernier, Geneva
Phone: +41 22 749 01 11
Email: copyright@iso.org
Website: www.iso.org
Published in Switzerland Reference number
ISO/FDIS 16328:2026(en) © ISO 2026
ii
ISO/FDIS 16328:2026(en)
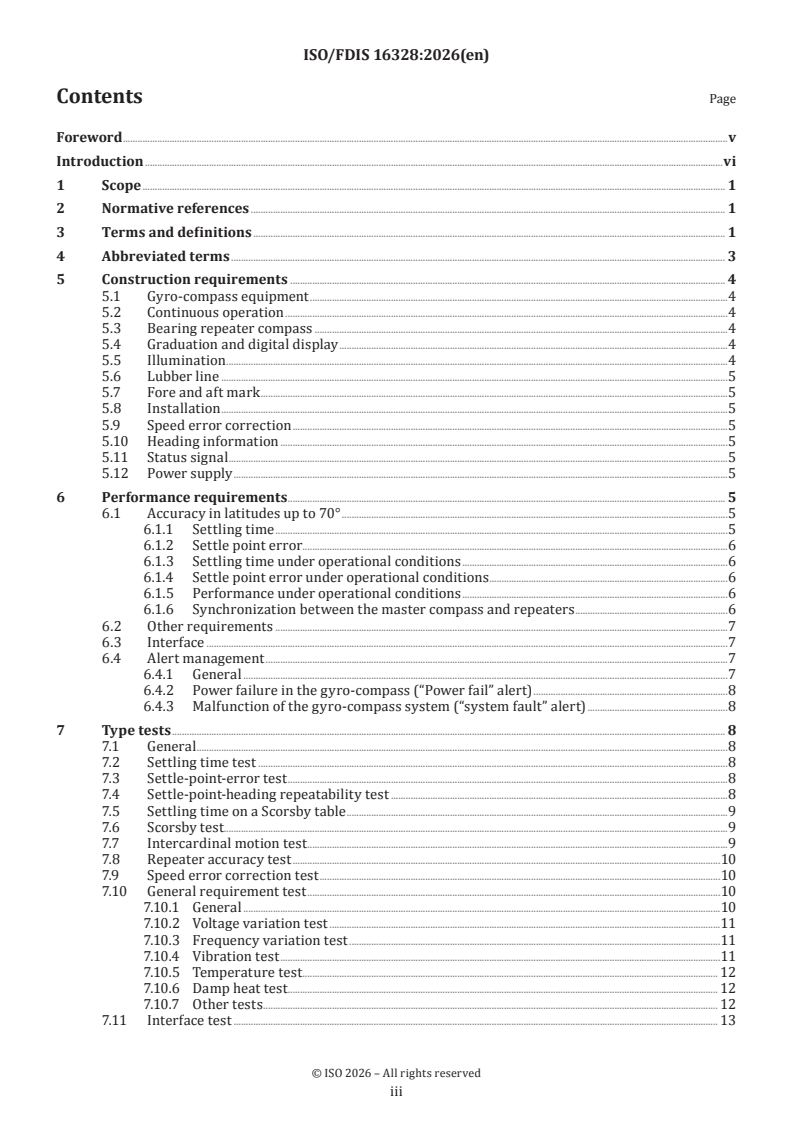
Contents Page
Foreword .v
Introduction .vi
1 Scope . 1
2 Normative references . 1
3 Terms and definitions . 1
4 Abbreviated terms . 3
5 Construction requirements . 4
5.1 Gyro-compass equipment .4
5.2 Continuous operation .4
5.3 Bearing repeater compass .4
5.4 Graduation and digital display .4
5.5 Illumination .4
5.6 Lubber line .5
5.7 Fore and aft mark .5
5.8 Installation .5
5.9 Speed error correction .5
5.10 Heading information .5
5.11 Status signal .5
5.12 Power supply .5
6 Performance requirements . . 5
6.1 Accuracy in latitudes up to 70° .5
6.1.1 Settling time .5
6.1.2 Settle point error .6
6.1.3 Settling time under operational conditions .6
6.1.4 Settle point error under operational conditions .6
6.1.5 Performance under operational conditions .6
6.1.6 Synchronization between the master compass and repeaters .6
6.2 Other requirements .7
6.3 Interface .7
6.4 Alert management .7
6.4.1 General .7
6.4.2 Power failure in the gyro-compass (“Power fail” alert) .8
6.4.3 Malfunction of the gyro-compass system (“system fault” alert) .8
7 Type tests . 8
7.1 General .8
7.2 Settling time test .8
7.3 Settle-point-error test .8
7.4 Settle-point-heading repeatability test .8
7.5 Settling time on a Scorsby table .9
7.6 Scorsby test.9
7.7 Intercardinal motion test .9
7.8 Repeater accuracy test .10
7.9 Speed error correction test .10
7.10 General requirement test .10
7.10.1 General .10
7.10.2 Voltage variation test .11
7.10.3 Frequency variation test .11
7.10.4 Vibration test .11
7.10.5 Temperature test . . 12
7.10.6 Damp heat test . . 12
7.10.7 Other tests . 12
7.11 Interface test . 13
iii
ISO/FDIS 16328:2026(en)
7.12 Alert management test . 13
7.12.1 Basic test for alert management . 13
7.12.2 “Power fail” alert or output of a status signal on the EUT power . 13
7.12.3 “system fault” alert . 13
8 Marking and identification .13
9 Information . 14
Annex A (normative) Requirements for ship surveyors for the installation of gyro-compasses
and repeater compasses on board crafts .15
Annex B (informative) Vehicle test . 16
Annex C (normative) Alerts definition for gyro-compasses . 17
Annex D (normative) IEC 61162 series interfaces for VDR and other external equipment .18
Bibliography .20
iv
ISO/FDIS 16328:2026(en)
Foreword
ISO (the International Organization for Standardization) is a worldwide federation of national standards
bodies (ISO member bodies). The work of preparing International Standards is normally carried out through
ISO technical committees. Each member body interested in a subject for which a technical committee
has been established has the right to be represented on that committee. International organizations,
governmental and non-governmental, in liaison with ISO, also take part in the work. ISO collaborates closely
with the International Electrotechnical Commission (IEC) on all matters of electrotechnical standardization.
The procedures used to develop this document and those intended for its further maintenance are described
in the ISO/IEC Directives, Part 1. In particular, the different approval criteria needed for the different types
of ISO document should be noted. This document was drafted in accordance with the editorial rules of the
ISO/IEC Directives, Part 2 (see www.iso.org/directives).
ISO draws attention to the possibility that the implementation of this document may involve the use of (a)
patent(s). ISO takes no position concerning the evidence, validity or applicability of any claimed patent
rights in respect thereof. As of the date of publication of this document, ISO had not received notice of (a)
patent(s) which may be required to implement this document. However, implementers are cautioned that
this may not represent the latest information, which may be obtained from the patent database available at
www.iso.org/patents. ISO shall not be held responsible for identifying any or all such patent rights.
Any trade name used in this document is information given for the convenience of users and does not
constitute an endorsement.
For an explanation of the voluntary nature of standards, the meaning of ISO specific terms and expressions
related to conformity assessment, as well as information about ISO's adherence to the World Trade
Organization (WTO) principles in the Technical Barriers to Trade (TBT), see www.iso.org/iso/foreword.html.
This document was prepared by Technical Committee ISO/TC 8, Ships and marine technology, Subcommittee
SC 6, Navigation and ship operations.
This third edition cancels and replaces the second edition (ISO 16328:2014), which has been technically
revised.
The main changes are as follows:
— Clause 4 (abbreviated terms) has been added;
— in 6.4, requirements related to bridge alert management have been added;
— in 7.1, a requirement for display equipment has been added;
— in 7.12, a test method for requirements related to bridge alert management has been added;
— Annex C has been replaced with a new Annex on alerts definition, including alert identifiers;
— in Annex D, an IEC 61162 series interfaces overview has been added;
— the normative references and bibliography have been updated.
Any feedback or questions on this document should be directed to the user’s national standards body. A
complete listing of these bodies can be found at www.iso.org/members.html.
v
ISO/FDIS 16328:2026(en)
Introduction
[ ]
This document is aligned with IMO Resolution A.821(19) 3 on performance standards for gyro-compasses
for high-speed craft.
Any text in this document which is a citation from the IMO Resolution A.821(19), appears in italics. Within
these citations, any changes to the original wording of the IMO Resolution A.821(19) are written in upright
font.
In this document, the following verbal forms are used:
— “shall” indicates a requirement;
— “should” indicates a recommendation;
— “may” indicates a permission;
— “can” indicates a possibility or a capability.
vi
FINAL DRAFT International Standard ISO/FDIS 16328:2026(en)
Ships and marine technology — Gyro-compasses for high-
speed craft
1 Scope
This document specifies the minimum requirements, construction, performance and type testing for gyro-
compasses for high-speed craft, which are required to comply with the International Convention for the
[4]
Safety of Life at Sea (SOLAS) 1974 (as amended), Chapter X and the performance standards adopted by the
[3]
IMO Resolution A.821(19).
2 Normative references
The following documents are referred to in the text in such a way that some or all of their content constitutes
requirements of this document. For dated references, only the edition cited applies. For undated references,
the latest edition of the referenced document (including any amendments) applies.
IEC 60945, Maritime navigation and radiocommunication equipment and systems — General requirements —
Methods of testing and required test results
IEC 61162-1, Marine navigation and radiocommunication equipment and systems — Digital interfaces — Part 1:
Single talker and multiple listeners
IEC 61162-2, Maritime navigation and radiocommunication equipment and systems — Digital interfaces — Part
2: Single talker and multiple listeners, high-speed transmission
IEC 61162-450, Maritime navigation and radiocommunication equipment and systems - Digital interfaces - Part
450: Multiple talkers and multiple listeners - Ethernet interconnection
IEC 62288, Maritime navigation and radiocommunication equipment and systems — Presentation of navigation-
related information on shipborne navigational displays — General requirements, methods of testing and required
test results
IEC 62923-1, Maritime navigation and radiocommunication equipment and systems — Bridge alert management
— Part 1: Operational and performance requirements, methods of testing and required test results
IEC 62923-2, Maritime navigation and radiocommunication equipment and systems — Bridge alert management
— Part 2: Alert and cluster identifiers and other additional features
IMO Resolution A.424 (XI), Performance standards for gyro-compasses
IMO Resolution MSC.302(87), performance standards for bridge alert management
IMO Resolution MSC.191(79), Performance standards for the presentation of navigation-related information on
shipborne navigational displays
IMO Resolution A.694(17), General requirements for shipborne radio equipment forming part of the global
maritime distress and safety system (GMDSS) and for electronic navigational aids
3 Terms and definitions
For the purposes of this document, the following terms and definitions apply.
ISO/FDIS 16328:2026(en)
ISO and IEC maintain terminology databases for use in standardization at the following addresses:
— ISO Online browsing platform: available at https:// www .iso .org/ obp
— IEC Electropedia: available at https:// www .electropedia .org/
3.1
gyro-compass
complete equipment comprising all essential elements of the complete design, including both the gyro-
compass as heading sensor and the associated heading transmission system
[3]
[SOURCE: IMO Resolution A.821(19), 2.1, modified — “complete equipment comprising all essential
elements of the complete design” has been added]
3.2
true heading
horizontal angle between the vertical plane passing through the true meridian and the vertical plane passing
through the craft's fore and aft datum line
Note 1 to entry: The true heading is measured from true north (000°) clockwise through 360°.
Note 2 to entry: When the gyro-compass (3.1) equipment is tested on the test stand, this “true heading” is regarded as
the true heading of the lubber line. Where a gyro-compass has the facility of introducing a correction by moving the
lubber line, the correction is set for the local latitude.
[3]
[SOURCE: IMO Resolution A.821(19), 2.2, modified — notes 1 and 2 to entry have been added.]
3.3
settled
stable situation when any three readings taken at intervals of 30 min are within a band of 0,7°, with the
compass level and stationary
Note 1 to entry: The settling time is the elapsed time between the time of switch-on at the initial heading error and the
third recording of the settle.
[3]
[SOURCE: IMO Resolution A.821(19), 2.3, modified — note 1 to entry has been added.]
3.4
settle point heading
mean value of ten readings taken at 20 min intervals after the compass has settled (3.3)
[SOURCE: IMO Resolution A. 821(19), 2.4]
3.5
settle point error
difference between the settle point heading (3.4) and the true heading (3.2)
[3]
[SOURCE: IMO Resolution A.821(19), 2.5]
3.6
error
difference between the observed value and the settle point heading (3.4)
Note 1 to entry: In this document, if the true heading (3.2) is unknown —other than in the case of a settle point error
(3.13) (the difference from the true heading) — quantitative heading error is evaluated using the settle point heading
(3.4) instead of the true heading defined here.
[3]
[SOURCE: IMO Resolution A.821(19), 2.6, modified — note 1 to entry has been added.]
3.7
repeater compass
device that reproduces the master compass card at a remote location
ISO/FDIS 16328:2026(en)
3.8
bearing repeater compass
device that reproduces the master compass card for the purpose of taking bearings
3.9
compass card
graduated dial of the compass which indicates the measured direction of the meridian
3.10
latitude error
error (3.6) to which some gyro-compasses (3.1) are subject, the magnitude and sign of which depend upon
the local latitude
Note 1 to entry: Means are provided for correcting this error.
3.11
speed error
error (3.6) to which gyro-compasses (3.1) are subject, the magnitude and sign of which depend upon the
speed, course, and latitude of the craft
Note 1 to entry: Means are provided for correcting this error.
3.12
lubber line
index line situated on the body of gyro-compass or repeater compass against which the compass card is read
3.13
master compass
main compass unit which supplies the heading information to the repeaters and other navigational aids
3.14
Scorsby table
test machine which enables a platform to oscillate independently about three axes
Note 1 to entry: It is used to simulate the motion of a craft.
3.15
bridge alert management
BAM
overall concept for management, handling and harmonized presentation of alerts on the bridge
[SOURCE: IMO Resolution MSC.302(87), Appendix 1]
3.16
central alert management system
CAM system
combined functionality of the central alert management and the central alert management human machine
interface
[SOURCE: IMO Resolution MSC.302(87), Appendix 1]
4 Abbreviated terms
For the purposes of this document, the following abbreviated terms apply.
ISO/FDIS 16328:2026(en)
BAM bridge alert management
CAM central alert management
EUT equipment under test
GC gyro-compass
GNSS global navigation satellite system
SDME speed and distance measuring equipment
VDR voyage data recorder
5 Construction requirements
5.1 Gyro-compass equipment
[3]
In accordance with IMO Resolution A.821(19), Section 3, gyro-compass equipment shall include the provision
of a compass card or analogue repeater for steering purposes and equipment for the purpose of taking visual
bearing.
5.2 Continuous operation
The equipment shall be capable of continuous operation under conditions of vibration, humidity, change of
temperature, and variations of the power supply, as specified in 7.10.
5.3 Bearing repeater compass
For crafts which are required to carry a bearing repeater compass, the construction of these shall be as
follows.
a) The bearing repeater compass shall be designed to be fitted with an azimuth-reading device.
b) A gimbal mechanism shall be provided to enable the bearing repeater compass card to be held
horizontally against the craft's motion.
c) Any bearing repeater compass intended for use on an open deck shall be waterproof.
5.4 Graduation and digital display
[3]
In accordance with IMO Resolution A.821(19), Section 3, the compass card shall be graduated at equal
intervals of 1° or a fraction thereof.
The graduation error shall be less than ± 0,2°.
A numerical indication shall be provided at least at every 10°, starting from 000° clockwise through 360°.
A digital display may be provided. When a digital display is provided, the course shall be displayed as three digits
plus, optionally, a fourth digit indicating tenths of a degree. When a gyro-compass with digital display is used, it
shall incorporate a turning direction indicator.
5.5 Illumination
Adequate illumination shall be provided to enable the reading of all compass cards at all times. Facilities for
dimming shall be provided.
ISO/FDIS 16328:2026(en)
5.6 Lubber line
Devices using a compass card shall be provided with a lubber line to indicate the craft's heading.
5.7 Fore and aft mark
If technically necessary, the compass shall be marked in a way to facilitate installation so that the lubber
line lies in a vertical fore and aft plane of the craft, or parallel. Where a gyro-compass has the facility of
introducing a correction by moving the lubber line, the correction during installation shall be set to zero.
If such marks or identifications are not in the same vertical plane as the uncorrected lubber line, then the
horizontal angular relationship between them shall be clearly indicated in the manufacturer’s installation
instruction.
5.8 Installation
[3]
In accordance with IMO Resolution A.821(19), 6.1, the master compass and any repeaters used for taking
visual bearings shall be installed or adjusted in a craft with their fore and aft datum lines parallel to the craft’s
fore and aft datum line to within ± 0,5°. The lubber line shall be in the same vertical plane passing through the
centre of the card of the compass and shall be aligned accurately in the fore and aft direction.
Requirements for ship surveyors for the installation of gyro-compasses and repeater compasses on board
crafts shall be in accordance with Annex A.
5.9 Speed error correction
[3]
In accordance with IMO Resolution A.821(19), 6.2, means shall be provided for correcting the errors induced
by speed and latitude. An approved accurate speed source shall be used for automatic speed error corrections.
5.10 Heading information
[3]
In accordance with IMO Resolution A.821(19), 6.5, the gyro-compass shall be designed to enable heading
information to be provided to other navigational aids such as radar, ARPA, radio direction-finder, and heading
control system. The accuracy of the other navigational aids shall not be degraded, and shall continue to comply
with the standards specified for such aids.
5.11 Status signal
[3]
In accordance with IMO Resolution A.821(19), 6.3, a status signal shall be provided to indicate that the gyro-
compass is ready for use.
5.12 Power supply
[3]
In accordance with IMO Resolution A.821(19), Section 5, the gyro-compass shall be provided with or
connected to an uninterruptable power supply.
6 Performance requirements
6.1 Accuracy in latitudes up to 70°
6.1.1 Settling time
[3]
In accordance with IMO Resolution A.821(19), 4.1.1, when switched on in accordance with the manufacturer's
instructions, the compass shall settle within 6 h.
ISO/FDIS 16328:2026(en)
6.1.2 Settle point error
[3]
In accordance with IMO Resolution A.821(19), 4.1.2, the settle point error at any heading shall not
exceed ± 0,75° × secant latitude, and the RMS value of the differences between individual heading indications and
the mean value shall be less than 0,25° × secant latitude. In accordance with IMO Resolution A.821(19), 4.1.3,
the repeatability of settle point error from one run-up to another shall be wi
...
ISO/FDIS 16328:2026(en)
ISO/TC 8/SC 6
Secretariat: JISC
Date: 2026-04-3007-09
Ships and marine technology — Gyro-compasses for high-speed craft
Navires et technologie maritime — Compas gyroscopiques pour navires à grande vitesse
FDIS stage
ISO/FDIS 16328:2026(en)
All rights reserved. Unless otherwise specified, or required in the context of its implementation, no part of this publication
may be reproduced or utilized otherwise in any form or by any means, electronic or mechanical, including photocopying,
or posting on the internet or an intranet, without prior written permission. Permission can be requested from either ISO
at the address below or ISO’s member body in the country of the requester.
ISO copyright office
CP 401 • Ch. de Blandonnet 8
CH-1214 Vernier, Geneva
Phone: + 41 22 749 01 11
EmailE-mail: copyright@iso.org
Website: www.iso.org
Published in Switzerland
ii
ISO/FDIS 16328:2026(en)
Contents
Foreword . vi
Introduction . vii
1 Scope . 1
2 Normative references . 1
3 Terms and definitions . 2
4 Abbreviated terms . 4
5 Construction requirements . 4
5.1 Gyro-compass equipment . 4
5.2 Continuous operation . 4
5.3 Bearing repeater compass . 4
5.4 Graduation and digital display . 4
5.5 Illumination . 5
5.6 Lubber line . 5
5.7 Fore and aft mark . 5
5.8 Installation . 5
5.9 Speed error correction . 5
5.10 Heading information . 5
5.11 Status signal . 5
5.12 Power supply . 5
6 Performance requirements . 6
6.1 Accuracy in latitudes up to 70° . 6
6.2 Other requirements . 7
6.3 Interface . 7
6.4 Alert management . 8
7 Type tests . 8
7.1 General. 8
7.2 Settling time test . 9
7.3 Settle-point-error test . 9
7.4 Settle-point-heading repeatability test . 9
7.5 Settling time on a Scorsby table . 9
7.6 Scorsby test . 9
7.7 Intercardinal motion test . 10
7.8 Repeater accuracy test . 10
7.9 Speed error correction test . 11
7.10 General requirement test . 11
7.11 Interface test . 13
7.12 Alert management test . 14
8 Marking and identification . 14
9 Information . 14
Annex A (normative) Requirements for ship surveyors for the installation of gyro-compasses
and repeater compasses on board crafts . 16
Annex B (informative) Vehicle test . 17
Annex C (normative) Alerts definition for gyro-compasses . 18
Annex D (normative) IEC 61162 series interfaces for VDR and other external equipment . 19
Bibliography . 21
iii
ISO/FDIS 16328:2026(en)
Foreword . v
Introduction . vi
1 Scope . 1
2 Normative references . 1
3 Terms and definitions . 2
4 Abbreviated terms . 3
5 Construction requirements . 4
5.1 Gyro-compass equipment . 4
5.2 Continuous operation . 4
5.3 Bearing repeater compass . 4
5.4 Graduation and digital display . 4
5.5 Illumination . 4
5.6 Lubber line . 4
5.7 Fore and aft mark . 4
5.8 Installation . 5
5.9 Speed error correction . 5
5.10 Heading information . 5
5.11 Status signal . 5
5.12 Power supply . 5
6 Performance requirements . 5
6.1 Accuracy in latitudes up to 70° . 5
6.1.1 Settling time . 5
6.1.2 Settle point error . 5
6.1.3 Settling time under operational conditions . 5
6.1.4 Settle point error under operational conditions . 5
6.1.5 Performance under operational conditions . 6
6.1.6 Synchronization between the master compass and repeaters . 6
6.2 Other requirements . 6
6.3 Interface . 7
6.4 Alert management . 7
6.4.1 General. 7
6.4.2 Power failure in the gyro-compass (“Power fail” alert) . 7
6.4.3 Malfunction of the gyro-compass system (“system fault” alert) . 7
7 Type tests . 8
7.1 General. 8
7.2 Settling time test . 8
7.3 Settle-point-error test . 8
7.4 Settle-point-heading repeatability test . 8
7.5 Settling time on a Scorsby table . 8
7.6 Scorsby test . 9
7.7 Intercardinal motion test . 9
7.8 Repeater accuracy test . 9
7.9 Speed error correction test . 10
7.10 General requirement test . 10
7.10.1 General Information . 10
7.10.2 Voltage variation test . 10
7.10.3 Frequency variation test . 10
7.10.4 Vibration test . 10
7.10.5 Temperature test . 12
iv
ISO/FDIS 16328:2026(en)
7.10.6 Damp heat test . 12
7.10.7 Other tests . 12
7.11 Interface test . 12
7.12 Alert management test . 12
7.12.1 Basic test for alert management . 12
7.12.2 "Power fail” alert or output of a status signal on the EUT power . 13
7.12.3 "system fault” alert . 13
8 Marking and identification . 13
9 Information . 13
Annex A (normative) Requirements for ship surveyors for the installation of gyro- compasses
and repeater compasses on board crafts . 14
Annex B (informative) Vehicle test . 15
Annex C (normative) Alerts definition for gyro-compasses . 16
Annex D (normative) IEC 61162 interfaces for VDR and other external equipment . 17
Bibliography . 19
v
ISO/FDIS 16328:2026(en)
Foreword
ISO (the International Organization for Standardization) is a worldwide federation of national standards
bodies (ISO member bodies). The work of preparing International Standards is normally carried out through
ISO technical committees. Each member body interested in a subject for which a technical committee has been
established has the right to be represented on that committee. International organizations, governmental and
non-governmental, in liaison with ISO, also take part in the work. ISO collaborates closely with the
International Electrotechnical Commission (IEC) on all matters of electrotechnical standardization.
The procedures used to develop this document and those intended for its further maintenance are described
in the ISO/IEC Directives, Part 1. In particular, the different approval criteria needed for the different types of
ISO document should be noted. This document was drafted in accordance with the editorial rules of the
ISO/IEC Directives, Part 2 (see www.iso.org/directives).
ISO draws attention to the possibility that the implementation of this document may involve the use of (a)
patent(s). ISO takes no position concerning the evidence, validity or applicability of any claimed patent rights
in respect thereof. As of the date of publication of this document, ISO had not received notice of (a) patent(s)
which may be required to implement this document. However, implementers are cautioned that this may not
represent the latest information, which may be obtained from the patent database available at
www.iso.org/patents. ISO shall not be held responsible for identifying any or all such patent rights.
Any trade name used in this document is information given for the convenience of users and does not
constitute an endorsement.
For an explanation of the voluntary nature of standards, the meaning of ISO specific terms and expressions
related to conformity assessment, as well as information about ISO's adherence to the World Trade
Organization (WTO) principles in the Technical Barriers to Trade (TBT), see www.iso.org/iso/foreword.html.
This document was prepared by Technical Committee ISO/TC 8, Ships and marine technology, Subcommittee
SC 6, Navigation and ship operations.
This third edition cancels and replaces the second edition (ISO 16328:2014), which has been technically
revised.
The main changes are as follows:
— Clause 4, (abbreviated terms) has been added;
— Clause 4
— — in 6.46.4,, requirements related to bridge alert management have been added;
— — in 7.17.1,, a requirement for display equipment has been added;
— — in 7.127.12,, a test method for requirements related to bridge alert management has been added;
— Annex C— Annex C has been replaced with a new Annex on alerts definition, including alert identifiers .;
— — in Annex DAnnex D,, an IEC 61162 series interfaces overview has been added.;
— — the normative references and bibliography have been updated.
Any feedback or questions on this document should be directed to the user’s national standards body. A
complete listing of these bodies can be found at www.iso.org/members.html.
vi
ISO/FDIS 16328:2026(en)
Introduction
[3] ]
This document is aligned with IMO Resolution A.821(19) ) on performance standards for gyro-compasses
for high-speed craftscraft.
Any text in this document which is a citation from the IMO Resolution A.821(19), appears in italics. Within
these citations, any changes to the original wording of the IMO Resolution A.821(19) are written in upright
font.
In this document, the following verbal forms are used:
— — “shall” indicates a requirement;
— — “should” indicates a recommendation;
— — “may” indicates a permission;
— — “can” indicates a possibility or a capability.
vii
Final DRAFT International Standard ISO/FDIS 16328:2026(en)
Ships and marine technology — Gyro-compasses for high-speed craft
1 Scope
This document specifies the minimum requirements, construction, performance and type testing for gyro-
compasses for high-speed craftscraft, which are required to comply with the International Convention for the
[4] ]
Safety of Life at Sea (SOLAS) 1974 (as amended), ), chapter Chapter X and the performance standards
[3]
adopted by the IMO Resolution A.821(19).).
2 Normative references
The following documents are referred to in the text in such a way that some or all of their content constitutes
requirements of this document. For dated references, only the edition cited applies. For undated references,
the latest edition of the referenced document (including any amendments) applies.
IEC 60945, Maritime navigation and radiocommunication equipment and systems — General requirements —
Methods of testing and required test results
IEC 61162--1, Marine navigation and radiocommunication equipment and systems — Digital interfaces — Part
1: Single talker and multiple listeners
IEC 61162--2, Maritime navigation and radiocommunication equipment and systems — Digital interfaces —
Part 2: Single talker and multiple listeners, high-speed transmission
IEC 61162--450, Maritime navigation and radiocommunication equipment and systems - Digital interfaces - Part
450: Multiple talkers and multiple listeners - Ethernet interconnection
IEC 62288, Maritime navigation and radiocommunication equipment and systems — Presentation of navigation-
related information on shipborne navigational displays — General requirements, methods of testing and required
test results
IEC 62923--1, Maritime navigation and radiocommunication equipment and systems — Bridge alert
management — Part 1: Operational and performance requirements, methods of testing and required test results
IEC 62923--2, Maritime navigation and radiocommunication equipment and systems — Bridge alert
management — Part 2: Alert and cluster identifiers and other additional features
IMO Resolution A.424 (XI), Performance standards for gyro-compasses
IMO Resolution MSC.302(87), performance standards for bridge alert management
IMO Resolution MSC.191(79), Performance standards for the presentation of navigation-related information on
shipborne navigational displays
IMO Resolution MSC.466(101), Amendments to the performance standards for the presentation of navigation-
related information on shipborne navigational displays (Resolution MSC.191(79))
IMO Resolution A.694(17), General requirements for shipborne radio equipment forming part of the global
maritime distress and safety system (GMDSS) and for electronic navigational aids
ISO/FDIS 16328:2026(en)
3 Terms and definitions
For the purposes of this document, the following terms and definitions apply.
ISO and IEC maintain terminology databases for use in standardization at the following addresses:
— — ISO Online browsing platform: available at https://www.iso.org/obp
— — IEC Electropedia: available at https://www.electropedia.org/
3.1 3.1
gyro-compass
complete equipment comprising all essential elements of the complete design, including both the gyro-
compass as heading sensor and the associated heading transmission system
[3]
[SOURCE: IMO Resolution A.821(19),), 2.1, modified — “complete equipment comprising all essential
elements of the complete design” has been added]
3.2 3.2
true heading
horizontal angle between the vertical plane passing through the true meridian and the vertical plane passing
through the craft's fore and aft datum line
Note 1 to entry: The true heading is measured from true north (000°) clockwise through 360°.
Note 2 to entry: When the gyro-compass (3.1) equipment is tested on the test stand, this “true heading” is regarded as the
true heading of the lubber line. Where a gyro-compass has the facility of introducing a correction by moving the lubber
line, the correction is set for the local latitude.
[3]
[SOURCE: IMO Resolution A.821(19),), 2.2, modified — notes 1 and 2 to entry have been added.]
3.3 3.3
settled
stable situation when any three readings taken at intervals of 30 min are within a band of 0,7°, with the
compass level and stationary
Note 1 to entry: The settling time is the elapsed time between the time of switch-on at the initial heading error and the
third recording of the settle.
[3]
[SOURCE: IMO Resolution A.821(19),), 2.3, modified — note 1 to entry has been added.]
3.4 3.4
settle point heading
mean value of ten readings taken at 20 min intervals after the compass has settled (3.3(3.3))
[SOURCE: IMO Resolution A. 821(19), 2.4]
3.5 3.5
settle point error
difference between the settle point heading (3.4(3.4)) and the true heading (3.2(3.2))
[3]
[SOURCE: IMO Resolution A.821(19),), 2.5]
3.6 3.6
error
difference between the observed value and the settle point heading (3.4(3.4))
ISO/FDIS 16328:2026(en)
Note 1 to entry: In this document, if the true heading (3.2) is unknown —other than in the case of a settle point error
(3.13) (the difference from the true heading) — quantitative heading error is evaluated using the settle point heading
(3.4) instead of the true heading defined here.
[3]
[SOURCE: IMO Resolution A.821(19),), 2.6], modified — note 1 to entry has been added.]
3.7 3.7
repeater compass
device that reproduces the master compass card at a remote location
3.8 3.8
bearing repeater compass
device that reproduces the master compass card for the purpose of taking bearings
3.9 3.9
compass card
graduated dial of the compass which indicates the measured direction of the meridian
3.10 3.10
latitude error
error (3.6(3.6)) to which some gyro-compasses (3.1(3.1)) are subject, the magnitude and sign of which depend
upon the local latitude
Note 1 to entry: Means are provided for correcting this error.
3.11 3.11
speed error
error (3.6(3.6)) to which gyro-compasses (3.1(3.1)) are subject, the magnitude and sign of which depend upon
the speed, course, and latitude of the craft
Note 1 to entry: Means are provided for correcting this error.
3.12 3.12
lubber line
index line situated on the body of gyro-compass or repeater compass against which the compass card is read
3.13 3.13
master compass
main compass unit which supplies the heading information to the repeaters and other navigational aids
3.14 3.14
Scorsby table
test machine which enables a platform to oscillate independently about three axes
Note 1 to entry: It is used to simulate the motion of a craft.
3.15 3.15
bridge alert management
BAM
overall concept for management, handling and harmonized presentation of alerts on the bridge
[SOURCE: IMO Resolution MSC.302(87), Appendix 1]
ISO/FDIS 16328:2026(en)
3.16 3.16
central alert management system
CAM system
combined functionality of the central alert management and the central alert management human machine
interface
[SOURCE: IMO Resolution MSC.302(87), Appendix 1]
4 Abbreviated terms
For the purposes of this document, the following abbreviated terms apply.
BAM bridge alert management
CAM central alert management
EUT equipment under test
GC gyro-compass
GNSS global navigation satellite system
SDME speed and distance measuring equipment
VDR Voyage Data Recordervoyage data recorder
5 Construction requirements
5.1 Gyro-compass equipment
[3]
In accordance with IMO Resolution A.821(19), ), Section 3, gyro-compass equipment shall include the
provision of a compass card or analogue repeater for steering purposes and equipment for the purpose of taking
visual bearing.
5.2 Continuous operation
The equipment shall be capable of continuous operation under conditions of vibration, humidity, change of
temperature, and variations of the power supply, as specified in 7.107.10.
5.3 Bearing repeater compass
For crafts which are required to carry a bearing repeater compass, the construction of these shall be as follows.
a) a) The bearing repeater compass shall be designed to be fitted with an azimuth-reading device.
b) b) A gimbal mechanism shall be provided to enable the bearing repeater compass card to be held
horizontally against the craft's motion.
c) c) Any bearing repeater compass intended for use on an open deck shall be waterproof.
5.4 Graduation and digital display
[3]
In accordance with IMO Resolution A.821(19), ), Section 3, the compass card shall be graduated at equal
intervals of 1° or a fraction thereof.
The graduation error shall be less than ± 0,2°.
A numerical indication shall be provided at least at every 10°, starting from 000° clockwise through 360°.
ISO/FDIS 16328:2026(en)
A digital display may be provided. When a digital display is provided, the course shall be displayed as three digits
plus, optionally, a fourth digit indicating tenths of a degree. When a gyro-compass with digital display is used, it
shall incorporate a turning direction indicator.
5.5 Illumination
Adequate illumination shall be provided to enable the reading of all compass cards at all times. Facilities for
dimming shall be provided.
5.6 Lubber line
Devices using a compass card shall be provided with a lubber line to indicate the craft's heading.
5.7 Fore and aft mark
If technically necessary, the compass shall be marked in a way to facilitate installation so that the lubber line
lies in a vertical fore and aft plane of the craft, or parallel. Where a gyro-compass has the facility of introducing
a correction by moving the lubber line, the correction during installation shall be set to zero.
If such marks or identifications are not in the same vertical plane as the uncorrected lubber line, then the
horizontal angular relationship between them shall be clearly indicated in the manufacturer’s installation
instruction.
5.8 Installation
[3]
In accordance with IMO Resolution A.821(19),), 6.1, the master compass and any repeaters used for taking
visual bearings shall be installed or adjusted in a craft with their fore and aft datum lines parallel to the craft’s
fore and aft datum line to within ± 0,5°. The lubber line shall be in the same vertical plane passing through the
centre of the card of the compass and shall be aligned accurately in the fore and aft direction.
Requirements for ship surveyors for the installation of gyro-compasses and repeater compasses on board
crafts shall be in accordance with Annex AAnnex A.
5.9 Speed error correction
[3]
In accordance with IMO Resolution A.821(19),), 6.2, means shall be provided for correcting the errors induced
by speed and latitude. An approved accurate speed source shall be used for automatic speed error corrections.
5.10 Heading information
[3]
In accordance with IMO Resolution A.821(19),), 6.5, the gyro-compass shall be designed to enable heading
information to be provided to other navigational aids such as radar, ARPA, radio direction-finder, and heading
control system. The accuracy of the other navigational aids shall not be degraded, and shall continue to comply
with the standards specified for such aids.
5.11 Status signal
[3]
In accordance with IMO Resolution A.821(19),), 6.3, a status signal shall be provided to indicate that the gyro-
compass is ready for use.
5.12 Power supply
[3]
In accordance with IMO Resolution A.821(19), ), Section 5, the gyro-compass shall be provided with or
connected to an uninterruptable power supply.
ISO/FDIS 16328:2026(en)
6 Performance requirements
6.1 Accuracy in latitudes up to 70°
6.1.1 Settling time
[3]
In accordance with IMO Resolution A.821(19),), 4.1.1, when switched on in accordance with the
manufacturer's instructions, the compass shall settle within 6 h.
6.1.2 Settle point error
[3]
In accordance with IMO Resolution A.821(19),), 4.1.2, the settle point error at any heading shall not
exceed ± 0,75° × secant latitude, and the RMS value of the differences between individual heading indications and
the mean value shall be less than 0,25° × secant latitude. In accordance with IMO Resolution A.821(19), 4.1.3,
the repeatability of settle point error from one run-up to another shall be within 0,25° × secant latitude.
6.1.3 Settling time under operational conditions
[3]
In accordance with IMO Resolution A.821(19),), 4.2.1, when switched on in accordance with the
manufacturer's instructions, the compass shall settle within 6 h when rolling and pitching with simple harmonic
motion of any period between 6 s and 15 s, a maximum angle of 5°, and a maximum horizontal acceleration of
.
0,22 m/s
6.1.4 Settle point error under operational conditions
[3]
In accordance with IMO Resolution A.821(19),), 4.2.2, the repeatability of the settle point error of the master
compass shall be within ± 1° × secant latitude, including variations in magnetic fields likely to be experienced in
the craft in which it is installed.
6.1.5 Performance under operational conditions
[3]
In accordance with IMO Resolution A.821(19),), 4.2.3, in craft operating within a latitude band of 10°:°, the
following applies.
The requirements of 6.1.5 a)requirement specified in a) below shall be checked by means of simulation. The
requirements of 6.1.5specified in b) and 6.1.5 c) below shall also be checked by means of simulation and by a
vehicle test (sea or land)), if necessary. The vehicle test shall only be performed if there is an indication of a
physical problem or problems (see Annex BAnnex B for information). The vehicle test shall be performed
under realistic traffic conditions and the maximum acceleration in this test shall be in a band of 1 m/s to
2 m/s .
[3]
a) a) In accordance with IMO Resolution A.821(19),), 4.2.3.1, the residual steady-state error, after
1 1)
correction for speed and course influences at a speed of 70 kn , , shall not exceed ± 0,25° × secant latitude.
[3]
b) b) In accordance with IMO Resolution A.821(19),), 4.2.3.2, the maximum error due to a rapid
alteration of speed of 70 kn shall be kept to a minimum, and shall not exceed ± 2°. The horizontal
acceleration shall not exceed 2,0 m/s .
[3]
c) c) In accordance with IMO Resolution A.821(19),), 4.2.3.3, the error due to a rapid alteration of
course of 180° up to a maximum rate of turn of 20°/s in any azimuth direction up to a speed of 70 kn shall
not exceed ± 3°. The horizontal acceleration shall not exceed 2,0 m/s .
1 kn = 1,852 km/h.
1)
1 kn = 1,852 km/h.
ISO/FDIS 16328:2026(en)
[3]
d) d) In accordance with IMO Resolution A.821(19),), 4.2.3.4, the transient and steady-state errors
due to rolling, pitching, and yawing, with simple harmonic motions of any period between 6 s and 15 s,
maximum angles of 20°, 10°, and 5° respectively, and a maximum horizontal acceleration not exceeding
1 m/s , and at any course especially at 45°, 90°, and 315° shall not exceed ± 1° × secant latitude.
6.1.6 Synchronization between the master compass and repeaters
[3]
In accordance with IMO Resolution A.821(19),), 4.2.5, once the repeaters have been synchronized with the
master, the maximum divergence in reading between the master compass and repeater under all operational
conditions shall not exceed ± 0,5°. For the purposes of this requirement, the latitude and speed correction shall
be assumed equal to zero.
[3]
In accordance with IMO Resolution A.821(19),), 4.2.6, the follow-up rate of the transmission system shall be
at least 20°/s.
6.2 Other requirements
[3]
In accordance with IMO Resolution A.821(19),), 1.1, the gyro-compass shall determine the direction of the
head of the high-speed craftscraft (HSC) in relation to geographic (true) north.
[3]
In accordance with IMO Resolution A.821(19),), 1.2, in addition to the general requirements contained in IMO
Resolution A.694 (17), the gyro-compass equipment installed in craft operating under the following conditions
shall, as required by chapter 13 of the HSC Code, comply with the minimum performance requirements specified
in these standards:
a) 1 speed exceeding 30 kn and up to 70 kn;
b) 2 maximum rate of turn 20°/s;
c) 3 normal range of operation between 70° N and 70° S.
[3]
In accordance with IMO Resolution A.821(19),), 1.3, the gyro-compass, within a speed range of up to 30 kn,
shall comply with the requirements of IMO Resolution A.424 (XI), and within a speed range of 30 kn to 70 kn shall
comply with the requirements of IMO Resolution A.821(19).
Other requirements shall be in accordance with the relevant clauses in IEC 60945.
6.3 Interface
[3]
In accordance with IMO Resolution A.821(19), ), Section 7, the gyro-compasses equipment shall provide with
an output of heading information with an accuracy as defined in 6.1.66.1.6 when interfaced by other equipment.
The compass shall provide interface facilities which meet IEC 61162-1, IEC 61162-2 or IEC 61162-450.
The gyro-compass equipment shall provide an appropriate data source and at least one output of the heading
information. The heading output shall be updated at a rate of once every 20 ms. The THS sentence detailed in
IEC 61162-1 shall be provided for the heading information.
NOTE THS refers a sentence formatter which is described in IEC 61162-1.
The sentences from IEC 61162-1 shall be in accordance with Annex DAnnex D.
ISO/FDIS 16328:2026(en)
6.4 Alert management
6.4.1 General
[3]
In accordance with IMO Resolution A.821(19),), 6.4, an alert signal shall be provided to indicate that the gyro-
compass has suffered an external power supply failure or an internal system functional failure (i.e. malfunction)
which would invalidate the heading information.
If the gyro-compass uses display equipment for alert management, it shall comply with IMO Resolution
[5]
MSC.191(79), as amended by IMO Resolution MSC.466(101),), and with IEC 62288.
The general presentation, handling and communication for alerts shall comply with the requirements stated
in IMO Resolution MSC.302(87),); IEC 62923-1, Module A and Module C,; and IEC 62923-2, as a minimum.
The alerts with a standard alert identifier for gyro-compasses are specified in Table C.1Table C.1.
NOTE 1 Alert titles and alert description texts used in Table C.1Table C.1 and in the body text of this document are not
mandatory alert titles and alert description texts, but are regarded as guidance. Alert titles and alert description texts
used in the body text of this document are therefore indicated between double quotation marks (“ “).”).
The manufacturer of the gyro-compass shall declare the EUT function type for the bridge alert management
(BAM) compliance test.
NOTE 2 According to the EUT function type, the relevant test set-up and test items are specified in BAM test standards.
Refer to IEC 62923-1: EUT function types, Test methods, Module A and Module C.
6.4.2 Power failure in the gyro-compass (“Power fail” alert)
In the case of power failure of the gyro-compass, a status signal (e.g. by normally closed contact) shall be
provided to enable external equipment to raise the appropriate alert.
If the gyro-compass has another power supply for backup and can use display equipment during failure of one
power supply, the “power fail” alert may be provided as specified in Table C.1Table C.1.
6.4.3 Malfunction of the gyro-compass system (“system fault” alert)
When the self-diagnosis function of the gyro-compass detects the major malfunction of the system, the “system
fault” alert with an appropriate priority or the minimum presentation indicating the cause of failure shall be
activated as specified in Table C.1Table C.1.
In the case of the malfunction whereby the gyro-compass system cannot operate at all, the status signal (e.g.
by normally closed contact) shall be output as specified in 6.4.26.4.2 so that external equipment can raise a
proper alert.
7 Type tests
7.1 General
Unless otherwise stated in this document, confirm by inspection of documented evidence that the EUT
complies with IEC 60945 (e.g. by using the tests specified in 7.10.77.10.7).).
The construction of the EUT shall conformsconform to the requirements specified in Clause 5Clause 5.
If the EUT uses display equipment, confirm by inspection of documented evidence that the EUT complies with
IEC 62288.
ISO/FDIS 16328:2026(en)
7.2 Settling time test
The master compass of the EUT shall be securely positioned on a nominally level and stationary base. It shall
be energized from nominal value power supplies and started in accordance with the manufacturer's
instructions from an initial heading error (to east) of 30° or more.
Confirm by observation that the settling time meets the requirement specified in 6.1.16.1.1.
7.3 Settle-point-error test
When the master compass of the EUT has settled, confirm by observation that the settle point error conforms
to the requirements specified in 6.1.26.1.2.
7.4 Settle-point-heading repeatability test
The master compass of the EUT shall be started in accordance with the manufacturer's instructions from an
initial heading error (to east) of 30° or more and shall be allowed to settle.
The settle point heading shall be determined. The master compass of the EUT shall then be switched off for a
period of not less than 12 h and not more than 7 days. It is then started again from an initial heading error (to
west) of 30° or more, a
...